Lumbrical4 · full intrinsic-position task · closed chain · BETA
About this resource
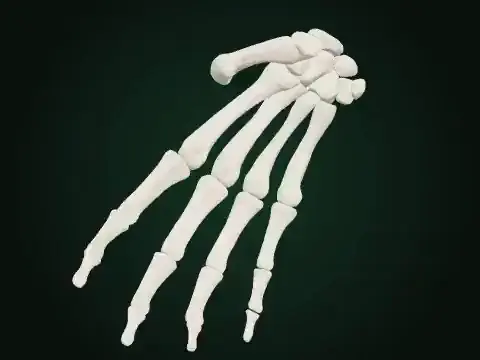
One common rigid transform expresses the same relative finger action with its declared phalangeal reference held. Object contact and grasp force are not solved. Published full active joint means from 195 healthy Indian volunteers aged 18–60, not universal maxima or muscle-specific capability. Each native bone shaft is calibrated to sagittal clinical straight; out-of-plane source morphology persists. Fixed source axes and common timing are authored, not measured joint coupling, tendon excursion, force or recruitment. This task illustrates MCP flexion with IP extension; full selected coronal components are separate finger-spread tasks. Extension tasks use the shared extensor mechanism, including real native hoods and bands; no single selected muscle is claimed to drive every IP endpoint alone. BETA teaching approximation; no clinical or faculty validation is claimed. Activity and geometric readouts are not muscle-force or patient measurements.
Inspect the selected source model and its visible limitations.
Model & sources
simLAB · original anatomy teaching source
Source-owned teaching illustration, not a clinical measurement. See the player for its scope and sources.